
LiberAI Introduces Liber-0 for Zero-Shot Robot Manipulation
Source: kitsapsun.com
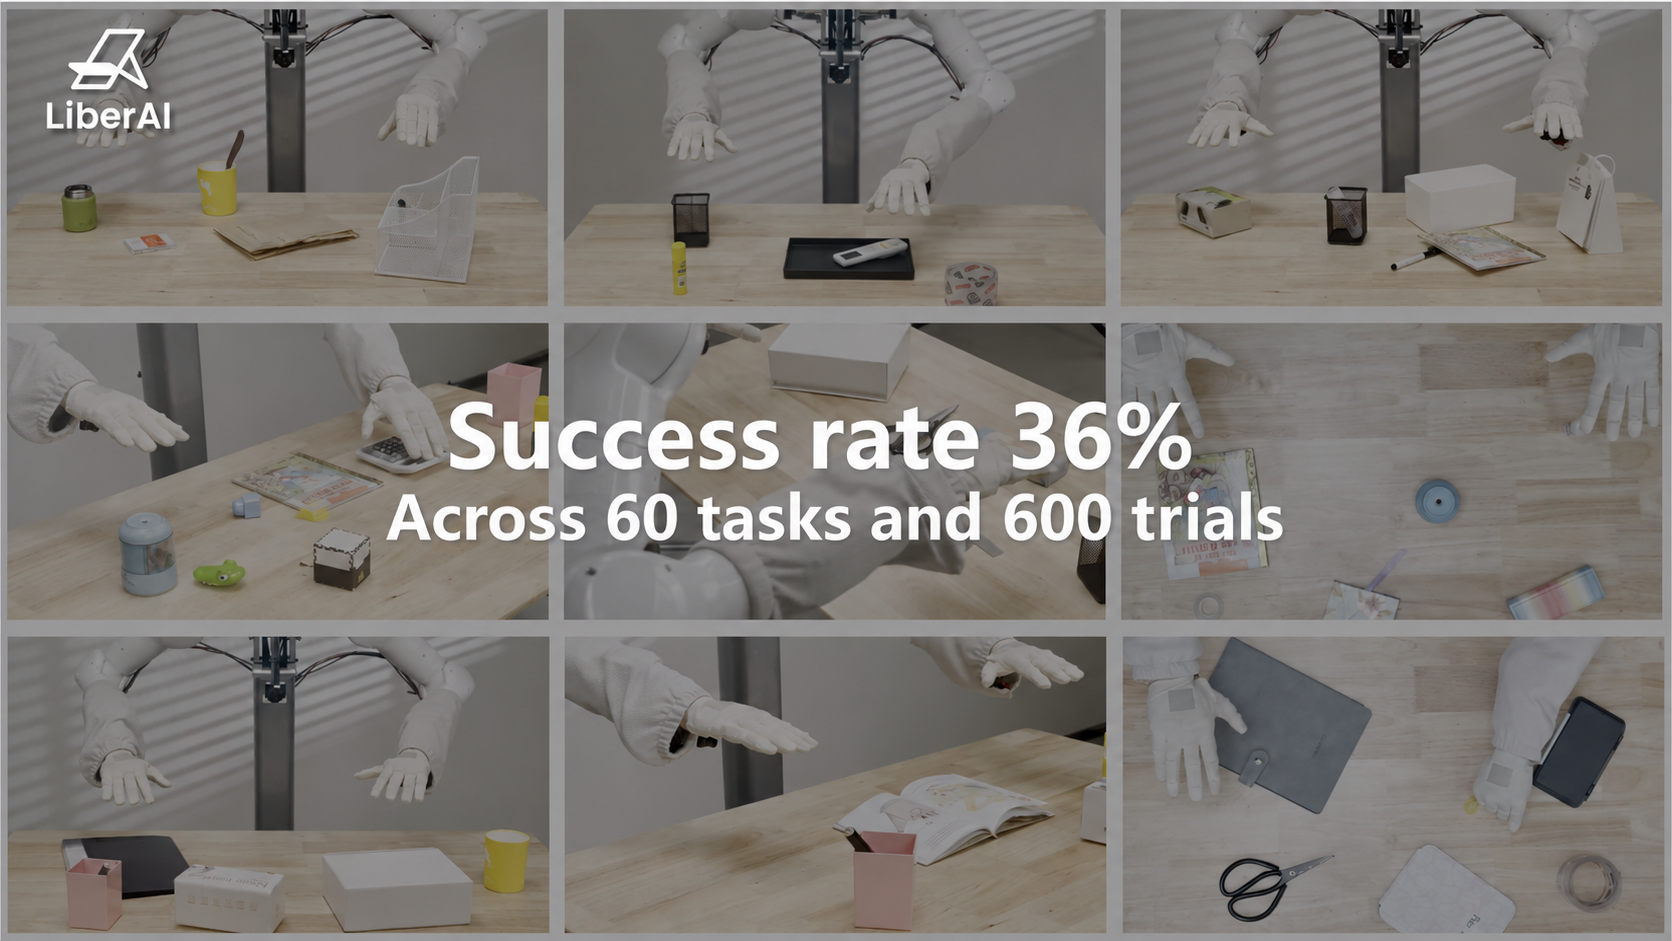
LiberAI introduced Liber-0, a World Action Model (WAM) that achieved a 36.0% overall success rate across 600 trials covering 60 robot manipulation tasks proposed by GPT-6, completing them without training on robot demonstrations collected specifically for those tasks. The evaluation covered 20 pick-and-place tasks, 20 other manipulation tasks, and 20 challenging non-pick-and-place and long-horizon tasks, each tested 10 times, with success rates of 63.5%, 34.0%, and 10.5% across the three groups. LiberAI defines this as task-level zero-shot generalization: the model was trained on robot data during pretraining but not on robot demonstrations collected for the evaluated tasks. Liber-0 learns from 2.2M+ hours of human experience. LiberAI addresses human-to-robot transfer through action grounding, using hand poses and trajectories recorded by LiberSense Glove to connect human video with measured physical actions, and embodiment alignment, with its LEO robotic platform incorporating dexterous hands, articulated wrists and waist, and camera configurations aligned with human data collection, plus a Unified Embodiment Representation telling the model about body dimensions and joint movement. In controlled single-source pretraining experiments followed by the same robot post-training, 10,000 hours of glove recordings outperformed 2 million hours of web human video on both pick-and-place and non-pick-and-place manipulation benchmarks.
SUCKS 0
0
0
Comments
This page shows all existing comments. To add a new comment, open the post in the forum.
No comments yet.